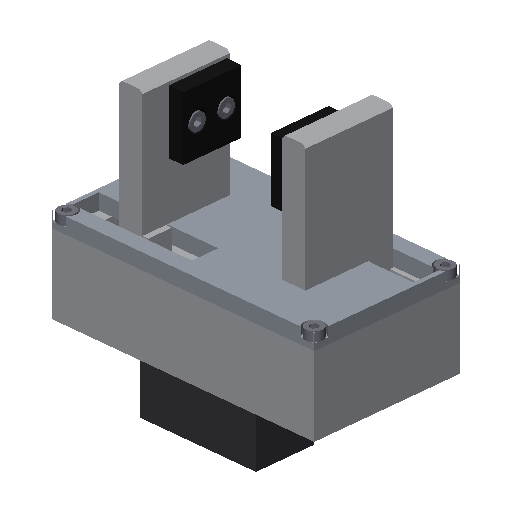
 Rack-and-pinion parallel servo gripper
Automation and robotics · Detailed spec
Rack-and-pinion parallel servo gripper
- jaw opening
- 0–60 mm
- parts
- 23
- mass
- 392 g
Download the CAD files
Free download. Open the full design in Luxxo CAD (opens in a new tab)
This rack-and-pinion parallel servo gripper was designed by the Luxxo CAD AI from a detailed-spec request. It has 23 parts, measures 91 × 51 × 97 mm and weighs 392 g, in aluminium 6061. Below you can read the request, the main specifications and the problems the AI flagged, and download the STEP, STL, DXF and A3 drawing for free.
The request
“Parallel-jaw robot gripper. Central pinion 20T module 1 on a standard 180° servo.”
First line of the request.
Specifications
- Jaw opening
- 0–60 mm
- Servo rotation
- 171.9° for full travel
- Grip force
- ≈ 50 N per jaw
- Robot flange
- 4 × M4 holes
Flagged by the AI
- The grip force acts 40–60 mm above the guide rod, so the moment rests on a 10 mm carrier bushing; a longer carrier or dual rods are needed for heavy loads.
Design your own in one sentence.
Describe a part or upload a hand sketch. 5 free designs, no card needed. Then from €9.
 Eight-station Geneva indexing demonstrator
 Ball screw linear actuator, 200 mm
 4-slot Geneva drive